A 26-Gram Tailless Butterfly-Inspired Flapping-Wing Robot with Onboard Attitude Control
Published in arXiv preprint arXiv:2602.06811, 2026
Preprint Spotlight
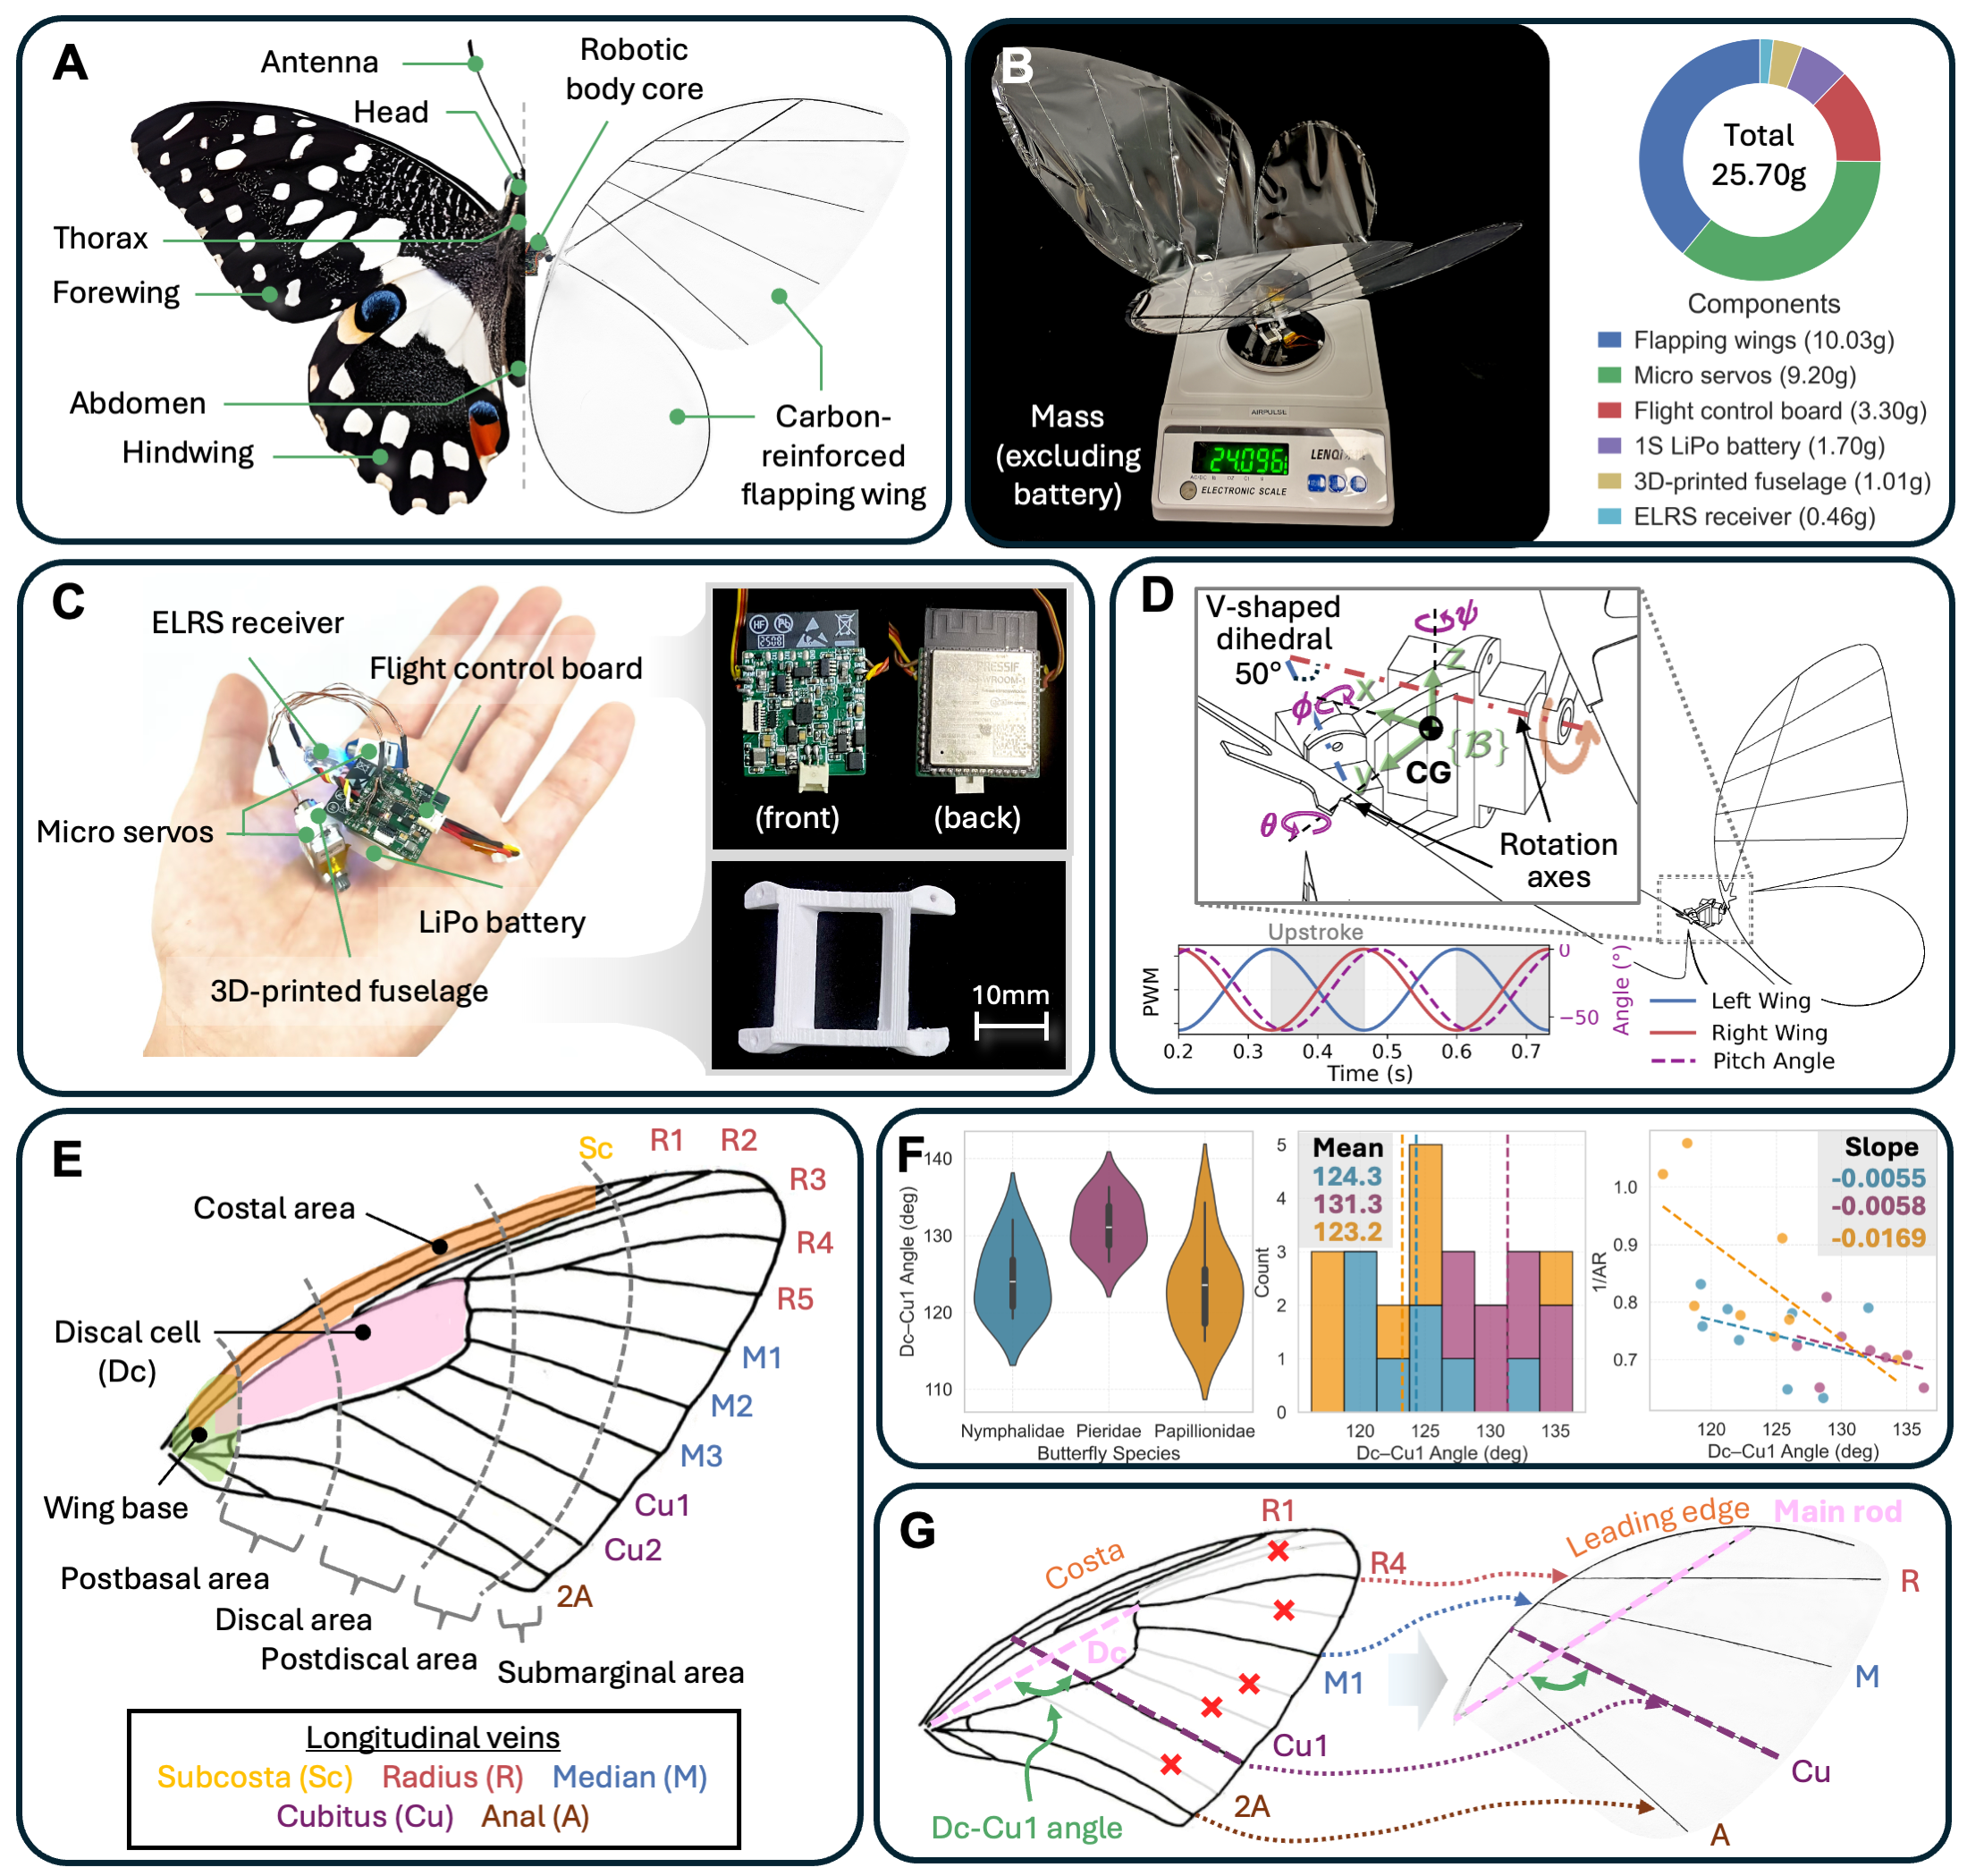
This work presents AirPulse, a 26-gram tailless butterfly-inspired flapping-wing robot with integrated sensing, computation, power, and onboard attitude control. The platform is designed to study lightweight bio-inspired flight where aerodynamics, mechanics, sensing, and control must work together as a single embodied system.
Why This Matters
Butterflies achieve agile flight with broad compliant wings and low-frequency actuation, but translating these principles into autonomous robots remains difficult because wingbeat-synchronous body dynamics and time-varying inertia complicate onboard control. AirPulse addresses this gap by combining bio-inspired flapping-wing design with onboard attitude control on an extremely lightweight platform.
Main Contributions
- Introduces AirPulse, a 26-gram two-winged tailless butterfly-inspired flapping-wing robot with integrated venation-inspired wings, sensing, computation, and power.
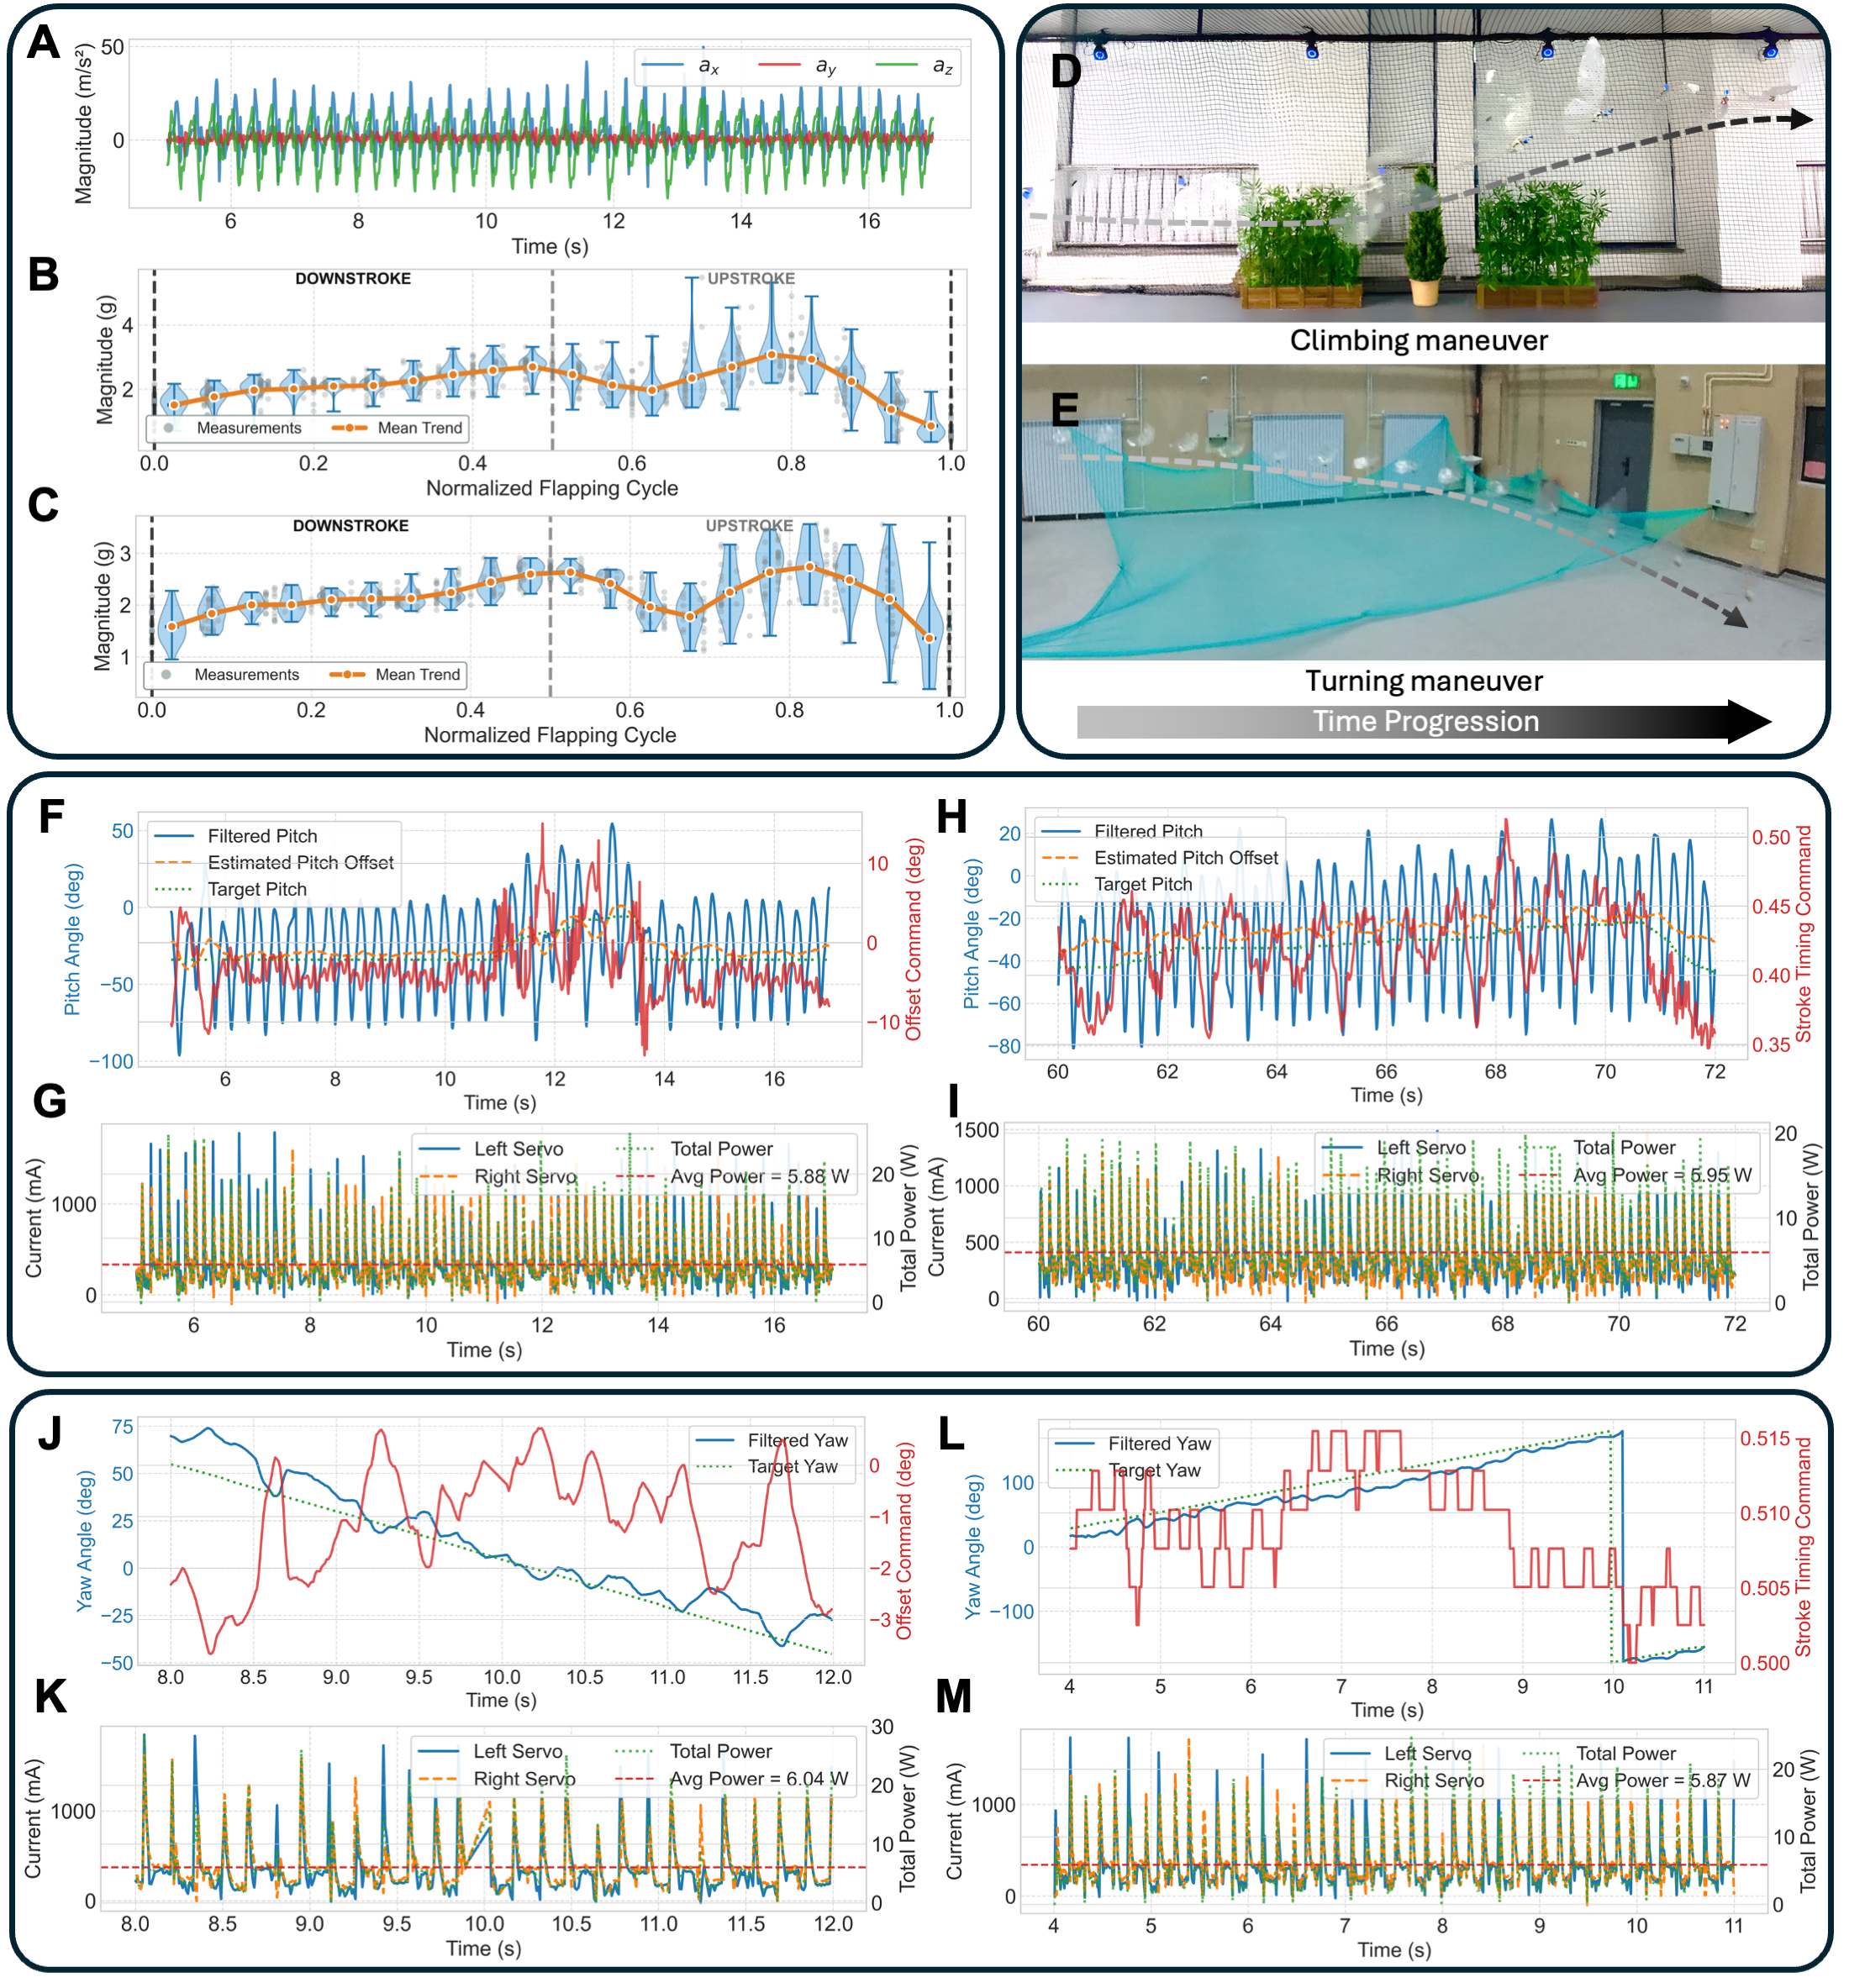
- Analyzes dynamic structural coupling and maps flapping-kinematic modulation parameters to experimental six-axis wrench profiles for control-channel allocation.
- Formulates Stroke Timing Asymmetry Rhythm (STAR), a phase-domain modulation strategy for smooth stroke-velocity changes while preserving mean flapping frequency.
- Demonstrates onboard feedback control for untethered pitch and directional tracking during climbing and turning maneuvers.
Key Findings
- AirPulse demonstrates stable untethered flapping motion with onboard feedback control.
- STAR provides a control interface for modulating flapping kinematics without disrupting the mean wingbeat frequency.
- The platform offers an experimentally validated basis for stabilizing strongly oscillatory, low-mass bio-inspired robots in sensitive or confined environments.
Citation
Gu, Weibin, Chenrui Feng, Lian Liu, Chen Yang, Xingchi Jiao, Yuhe Ding, Xiaofei Shi, Chao Gao, Alessandro Rizzo, and Guyue Zhou. “A 26-Gram Tailless Butterfly-Inspired Flapping-Wing Robot with Onboard Attitude Control.” arXiv preprint arXiv:2602.06811 (2026).